





Assistant Professor at Prince Sultan University · Robotics track lead at the RIOTU Lab



I build autonomous aerial robots — from the control and estimation math to the software that flies on real hardware. My work is strategic applied research aligned with Saudi Vision 2030: counter-UAS, GNSS-denied navigation, smart mobility and precision agriculture. My newer research thread is the intersection of AI and control.
- 🎓 PhD in Mechanical Engineering, KAUST — distributed planning for multi-robot systems
- 🏭 Former Lab Scientist at the Saudi Aramco R&D Center — inspection & in-pipe robots; co-inventor on 12 granted US patents
- 🧑🏫 I teach mobile robotics and UAVs, and graduate topics in control theory, model predictive control and vision-based drone control
- 🛠️ Most of what I build is open source here: PX4 + ROS 2 tooling, estimation, tracking and planning for drones
| Autonomy & control | Perception & estimation | Learning |
|---|---|---|
| Model predictive control Controller auto-tuning Multi-robot systems Counter-UAS interception |
Drone detection & tracking Sensor fusion & Kalman filtering GNSS-denied navigation (TERCOM, VIO, SLAM) |
AI + control Trajectory prediction Vision-language model benchmarking |
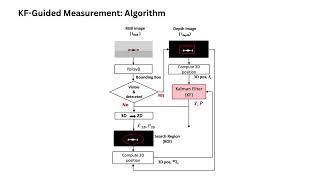
- SMART-TRACK — Kalman-filter-guided sensor fusion for robust UAV object tracking. IEEE Sensors Journal, 2024. [paper] [code] [video]
- VECTOR — velocity-enhanced GRU network for real-time 3D UAV trajectory prediction. Drones, 2025. [paper] [code] [dataset] [video]
- VLM benchmarking — vision-language models for automated quality control. Scientific Reports, 2026. [paper] [code]
- TERCOM-EKF vs. ViSensorRF — UAV localization in GNSS-denied environments. Results in Engineering, 2026. [paper] [code] [video]
- OCTUNE — optimal control tuning using real-time data. Sensors, 2022. [paper] [code] [PX4 interface] [video]
- D2DTracker — real-time trajectory prediction for agile drone-to-drone tracking. IEEE UVS, 2024. [paper] [detector] [prediction]
- FLIGHTGEN — ROS 2-powered automated UAV dataset generator. SMARTTECH, Springer LNNS, 2025. [paper] [code]
➡️ Full list on Google Scholar.
| Repository | Description | |
|---|---|---|
| px4_fast_planner | Fast-Planner integrated with PX4 for fast multi-rotor navigation with obstacle avoidance |  |
| mavros_apriltag_tracking | A PX4 multi-rotor tracking a moving vehicle using AprilTags |  |
| px4_pid_tuner | System identification and PID tuning of PX4 loops from flight logs |  |
| px4-flight-doctor | Diagnoses PX4 .ulg logs against your drone's real physical specs |
 |
| mavros_trajectory_tracking | Trajectory generation and tracking with a PX4 interface |  |
| mav_controllers_ros | ROS 2 implementations of micro-aerial-vehicle controllers |  |
| trajectory_generation | Trajectory generation, including model predictive control methods |  |
| Repository | Description | |
|---|---|---|
| multi_target_kf | Kalman filters for multi-target state estimation (ROS) |  |
| roboeye | Visual-inertial odometry on a Raspberry Pi |  |
| VINS-Fusion-ROS2-jazzy | VINS-Fusion ported to ROS 2 Jazzy |  |
| jetson_vins_fusion_docker | GPU VINS-Fusion in Docker on NVIDIA Jetson |  |
| imu_calib | ROS 2 package for computing and applying IMU calibration |  |
| Repository | Description | |
|---|---|---|
| siyi_sdk | Python SDK for SIYI gimbal-camera systems |  |
| siyi_ros2 | ROS 2 Jazzy driver for SIYI gimbals (ZT30, ZT6, ZR30, ZR10, A8 Mini, A2 Mini) |  |
| rtsp_camera | Low-latency RTSP camera streams into ROS 2 via GStreamer |  |
| raspberrypi_ai_camera_ros2 | ROS 2 package for the Raspberry Pi AI Camera (IMX500) |  |
| ZLAC8030L_CAN_controller | CANopen control of the ZLAC8030L motor driver |  |
| Repository | Description | |
|---|---|---|
| px4_ros2_humble | Docker development environment for PX4 + ROS 2 Humble |  |
| conveyor_sim_ros2 | Conveyor-belt simulation in Gazebo Harmonic with a ROS 2 interface |  |
| containers | Reusable Docker containers for robotics development |  |
| Repository | Description | |
|---|---|---|
| cortex | Self-hosted lab asset & inventory management — QR-scan checkout, reservations, low-stock alerts |  |
Robotics



Languages


AI & perception


Tools


 |
 |
| SMART-TRACK: sensor-fusion target tracking | VECTOR: GRU trajectory prediction |
 |
 |
| TERCOM: GNSS-denied navigation | OCTUNE: real-time controller tuning |
 |
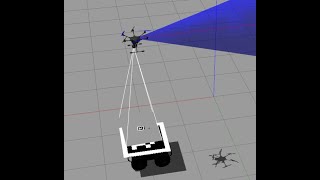 |
| Obstacle-free navigation with PX4 + Fast-Planner | Vision-based tracking of a moving vehicle |
 |
 |
| PSU on-campus drone delivery | Multi-drone search and pick |
Students interested in drones, control or robot learning at PSU — reach out through the RIOTU Lab.