



I build ML systems and robot perception, with reproducible evaluations. Seeking machine learning / AI and robotics engineering roles. M.S. Artificial Intelligence and B.S. Computer Science, Oregon State University.
Portfolio · Résumé · LinkedIn · Email
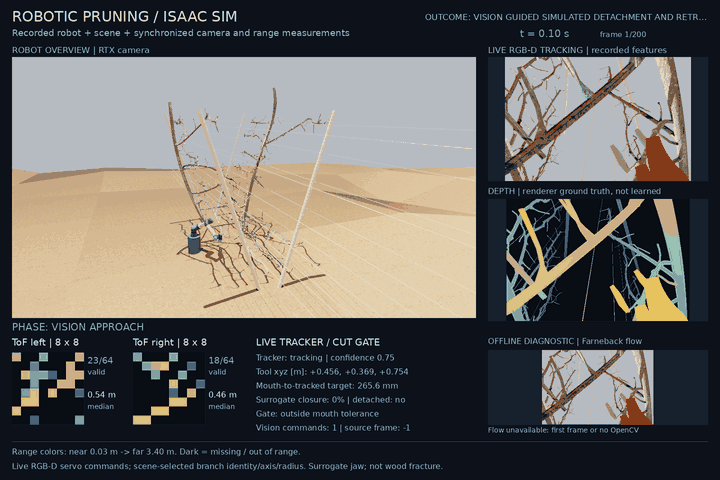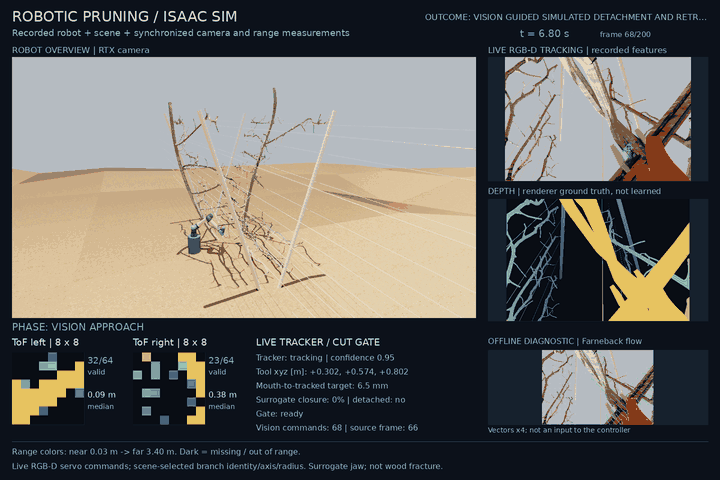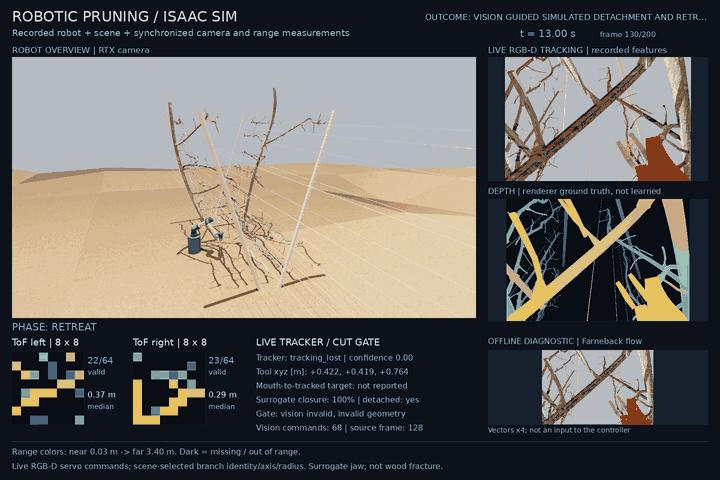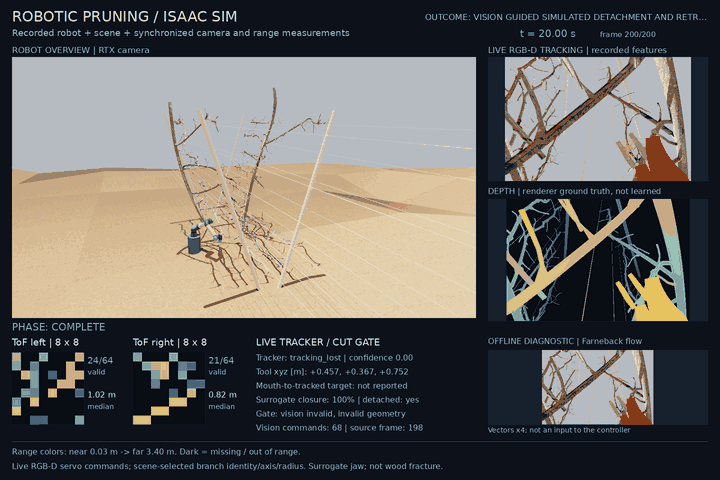
One controlled Isaac Sim episode. Classical RGB-D tracking, simulator depth and rigid-piece release; this is not a learned pruning policy or a wood-fracture model.
| Project | What I built | Evidence and limits |
|---|---|---|
| SPUR metric depth | Synthetic depth models, FastAPI inference and split ONNX export. | Encoder parity max difference 1.53e-5; V100 fp16 model p50 156 ms per six-view group. Field accuracy remains unverified. |
| Humanoid Robustness Ladder | Isaac Lab curricula, ONNX/MuJoCo evaluation and seeded failure controls. | Known-route Isaac task: 380/384 first episodes with sensor noise on; a delay-randomized fine-tune restores 32/32 under a 20 ms IMU lag. Unseen random mazes mapped by the robot's own lidar: 24/24 in MuJoCo (oracle pose). No hardware-transfer claim. |
| LeHome garment folding | SmolVLA fine-tuning in Isaac Sim on Slurm: restartable driver, simulator-validated recovery search, preregistered matched evaluation. | Found and fixed an optimizer defect that froze ~88% of trainable parameters in every earlier fine-tune. Best candidate vs baseline, measured side by side: H10 8/16 vs 5/16 (p = 0.24), H50 7/16 vs 7/16 — no improvement under the preregistered rule; the gain is pose-specific. 27 settled folds recorded with hashes. |
| Vision-guided pruning | RGB-D control, dual-ToF release checks, an independent recording grader and a ROS 2 software-in-the-loop node. | Pre-registered sweeps: 0/40 on seeded tree0 spurs and 0/40 again under three labelled approach strategies, published with a failure taxonomy; 2/7 pass (17/17 checks, Wilson 0.08–0.64) on the export's listed tree1 spurs. ROS 2 node matches the Python controller 199/199. Frozen depth model loses 6–8× at evening on 8/8 rendered trees (shading, not exposure; no test-time curve fixes it) and floors at 0.6–0.9 m below 0.4 m range; one metric range fixes UFO daylight (0.19→0.06 m), not Envy. Known target, classical tracking, rigid-piece release. |
| MetaNaviT | Retrieval and data APIs in a six-person team; solo follow-up: hybrid retrieval benchmark served over Postgres. | BEIR SciFact, 300 queries: reranked hybrid +0.075 nDCG@10 over BM25 (95% CI 0.053 to 0.101); our BM25 matches Anserini within 0.002. LLM-judge gate not yet evaluable. |
Python, PyTorch, OpenCV, Isaac Sim / Isaac Lab, MuJoCo, ONNX Runtime, FastAPI and Slurm. I connect model outputs to measurable behavior, document failure cases, and keep demos linked to the code and evaluation that support them.
The portfolio provides short visual case studies; the repositories contain setup, architecture, results and current limitations.